Cheverton Robotics
Give useful work
a physical form.
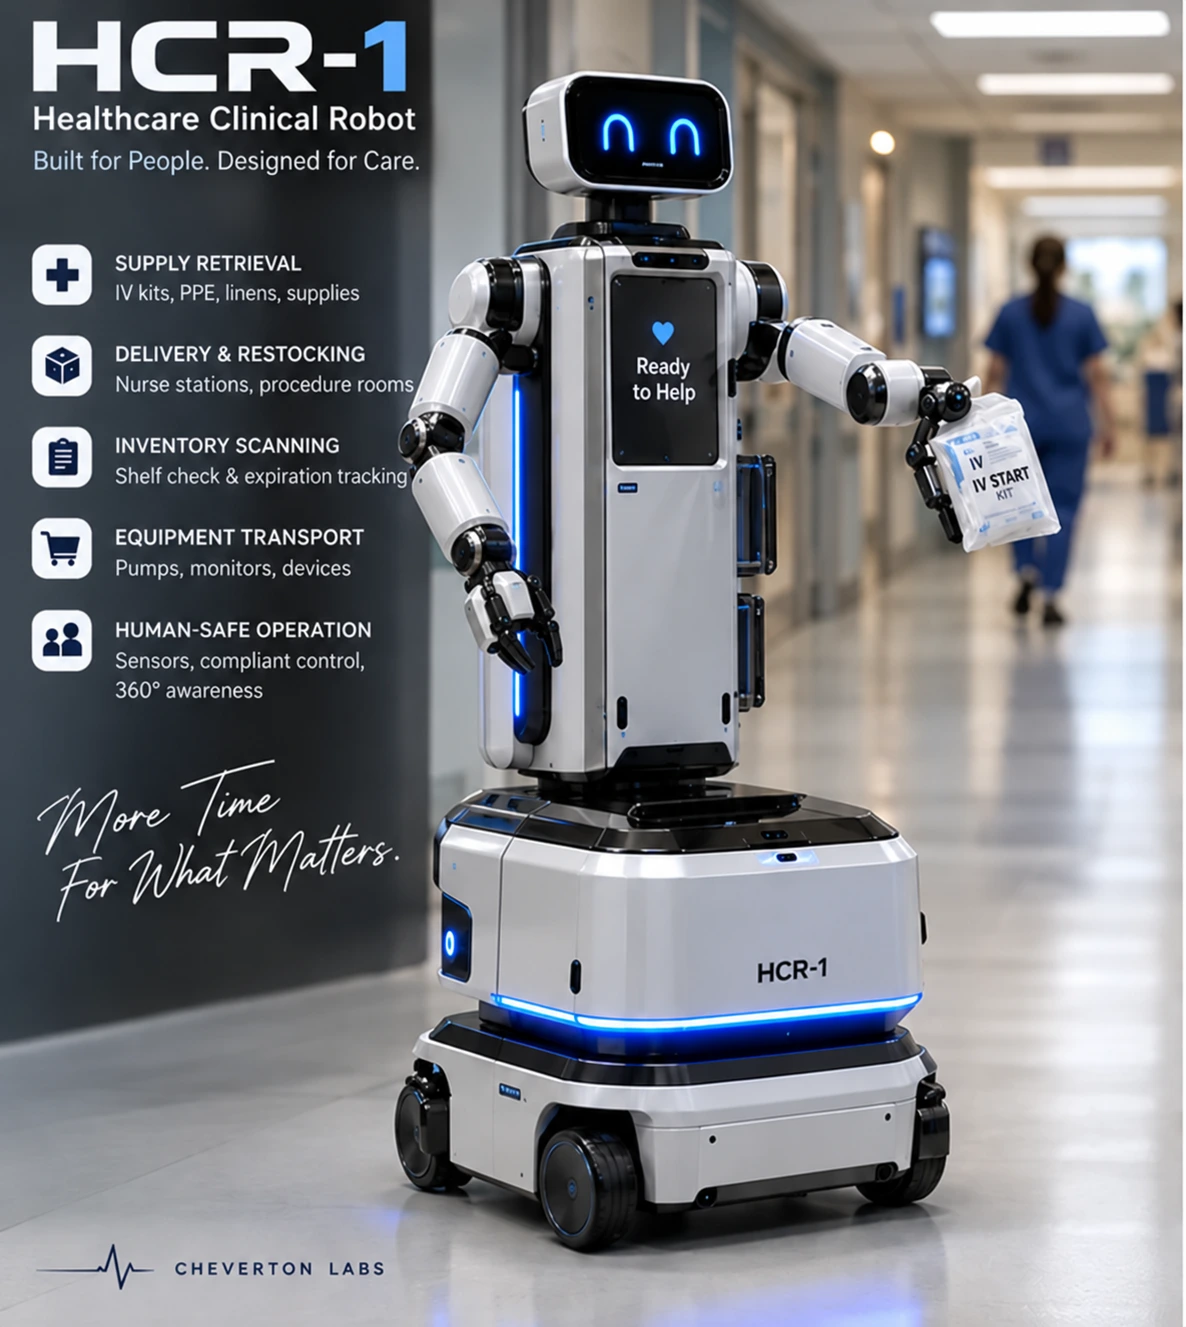
HCR-1 is a dual-arm mobile concept for packaged-supply retrieval and restocking. Engineering preparation precedes a physical prototype or hospital trial.
CHEVERTON ROBOTICS / THE MECHANICAL LION
Precision.
With a presence.
Our steel lion comes to life with a mechanical roar. Hover to animate, or use the controls. Sound is off until you choose it.
HCR-1 / A DEFINED FIRST TASK
Retrieve supplies.
Restock with care.
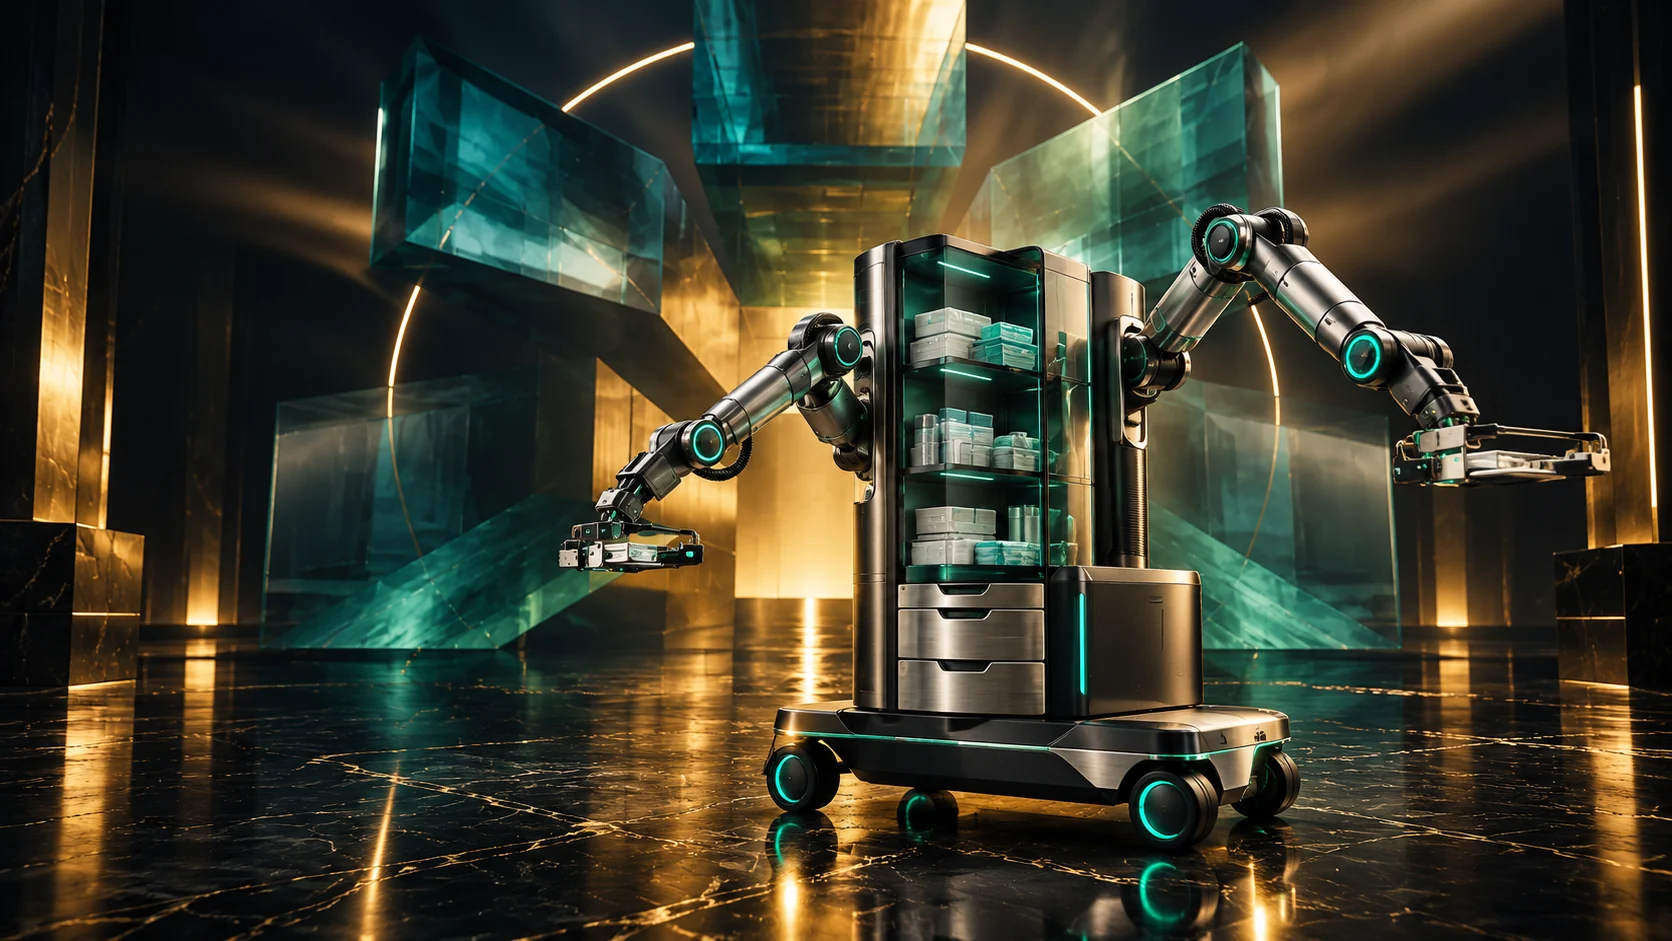
Explore packaged-supply retrieval and restocking from known storage locations, with the mobile base stopped during initial manipulation. Patient care, medication administration and clinical actions are outside this feasibility scope.
Two proposed manipulators; the historical arm reference uses seven axes per arm, with final joint count and geometry still under review. No payload rating is established.
Next evidence: reviewed geometry and loads, traceable components, simulation, a bench plan and qualified safety review. No physical prototype or hospital trial is represented.
Inspect the arm reference ↗Explore the complete concept ↗